Equipment / mechanism and fit
MATCH THE MACHINE TO THE ROW
A cleaning robot is a mobile maintenance tool that must make a controlled journey over a particular array. Start with the journey and the contact surface; compare machines only after the site's constraints are visible.
Read the whole working cycle
Selection is often reduced to brush type or headline coverage. On a utility-scale installation, the relevant unit is the complete cycle: getting equipment to the block, placing it safely, starting it, moving across intended modules, negotiating edges or row changes, returning it, and recording its condition. Every transfer and handoff is an operational step. If the plan cannot explain who performs it and how an interruption is handled, the equipment fit is not yet established.
A productive evaluation separates three questions: can the mechanism reach and travel through the planned area; is its contact method consistent with module and equipment guidance; and can the operation be supported by the site team under realistic weather and access conditions? These are related, but a positive answer to one does not guarantee the others.
Equipment anatomy
Look beyond the brushTravel and support
Wheels, tracks, rollers or other support elements determine how a cleaner crosses a row and what it relies on for traction or guidance. Check clearances, frame geometry, surface transitions and the effects of debris. Establish how the unit behaves at array edges and around gaps, not just on a convenient straight run.
Cleaning contact
Brushes and other contact components vary in material, pressure, rotation and layout. A dry method may suit some loose deposits, while adhered material can call for a different approved approach—or a decision not to clean mechanically. Abrasion, surface treatment, seals and frame details belong in the compatibility review.
Power and control
Battery, charging, command, sensing and stop functions define the practical work window. Ask how an operator confirms operating state, pauses or isolates the machine, identifies a fault and retrieves it. A control feature is useful only when the crew knows its limits and the response procedure.
Transfer and recovery
Consider loading, row-to-row movement, parking and recovery as part of the equipment, even when a person performs those tasks. Handling points, weight, access equipment and safe storage can determine whether a system remains practical across a large installation.
Check compatibility in context
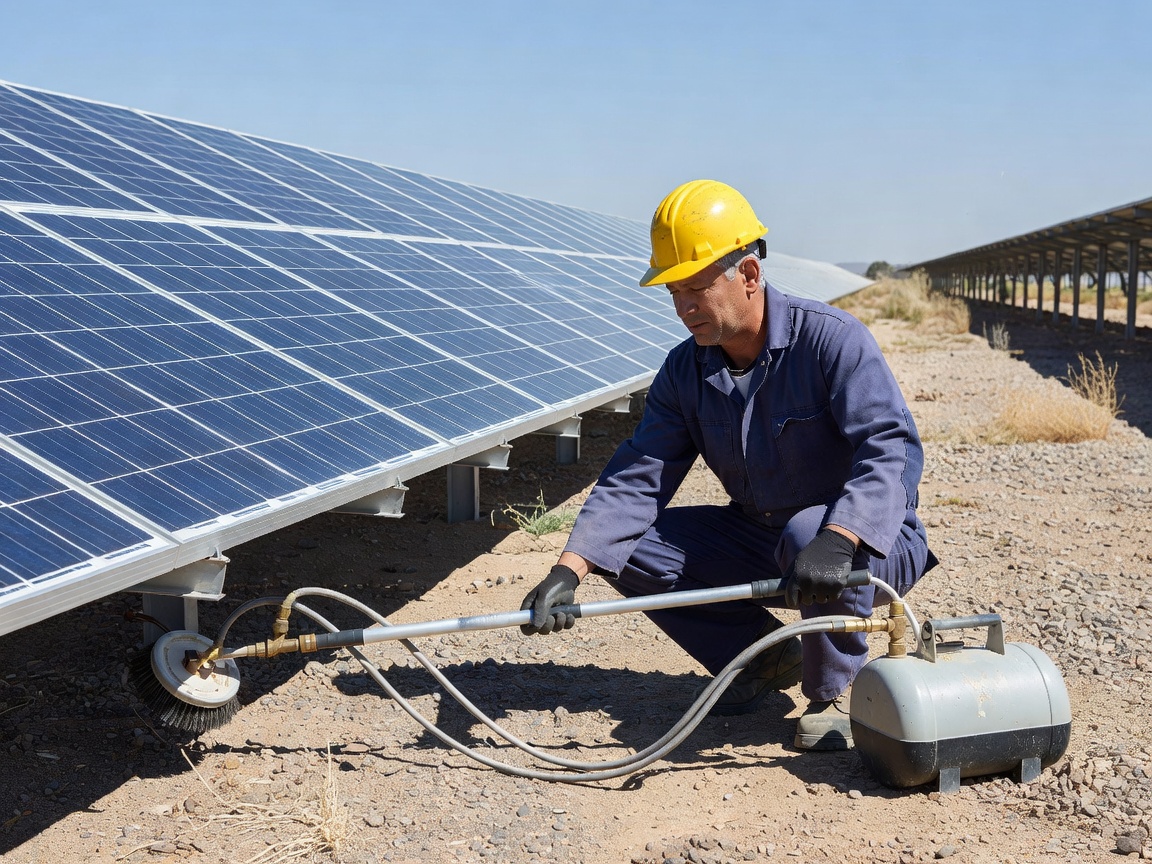
Collect the module model and installation information available to the operator, the maker's cleaning recommendations, site drawings and the proposed equipment instructions. Compare module dimensions, inclination, frame and clamp arrangement, row spacing and the robot's specified operating envelope. If the system relies on a frame edge or other feature for travel, verify that feature is continuous and suitable across the intended area.
Then organise a controlled trial. Choose a representative section that includes the ordinary route and any known variation. Agree the start and finish points, supervision, stop conditions, inspection criteria and recordkeeping beforehand. Photograph or otherwise document the initial condition using a repeatable method. A trial can reveal operational friction, but it cannot substitute for manufacturer compatibility guidance or a robust assessment of unusual conditions.
Ask the operator questions
How is the cleaner brought to the array? How does it stay on its intended route? What prevents contact with cabling, junction boxes or obstructions? What happens at a row end, interruption or loss of power? How does the unit communicate an incomplete run? Where is it stored between tasks, and who checks it before the next shift? Answers should be specific to the proposed site, not inferred from a demonstration on a different array.
Ask also what the equipment cannot establish. A robot's travel record is not automatically evidence that every module received an effective cleaning pass. A sensor may report position or a machine state without verifying glass cleanliness. Define the evidence required for the team's actual decision and a separate inspection step if the task needs one.
Compare mechanisms without ranking them
| Design question | What to inspect | Operational implication |
|---|
| How does it travel? | Support, guidance, edge behaviour, transitions | Sets row compatibility and recovery requirements. |
| What contacts glass? | Brush or contact material, pressure, motion and instructions | Influences deposit suitability and surface-care review. |
| How is it powered? | Runtime conditions, charging, isolation and indication | Shapes scheduling, supervision and maintenance handoff. |
| How is it moved between blocks? | Handling points, access and storage needs | Can affect crew size, timing and safe handling arrangements. |
Use current manufacturer instructions and the module supplier's cleaning guidance for the specific installation.
Where a good match can still fail
A suitable mechanism does not make all weather acceptable, remove debris hazards or resolve site access. Dust can collect differently along an array; a row may include repairs or altered components; and an otherwise routine pass can encounter a loose cable or unexpected obstruction. Keep a way to pause work, inspect the route and record exceptions. Resist turning a trial observation into a promise about future output or universal suitability.
Before authorising recurring runs, capture the agreed working area, approved contact method, operational limits, supervision and response arrangements. Review those assumptions when module types, site layout, equipment or local conditions change.
Check site fit Plan equipment upkeep